Hello! I'm
Tanmay Chhatbar
Doctoral Candidate at Clemson University (CU-ICAR)
Doctoral Candidate at Clemson University (CU-ICAR)


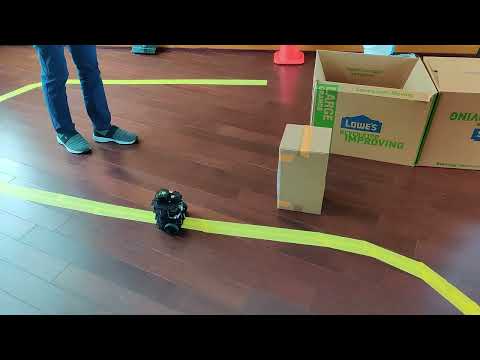
The Turtlebot3 is equipped with a Raspberry Pi 4 computer which is responsible for much of the onboard data processing and publishing.
OpenCR board is in charge of receiving commands from the Pi and powering and controlling power-intensive components including servos, motors, LiDAR and camera(s).
Computationally intensive tasks were offloaded onto a more powerful Linux laptop.
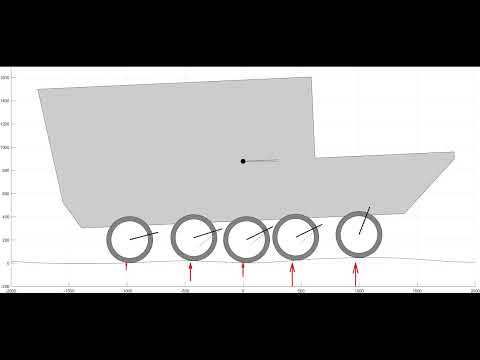
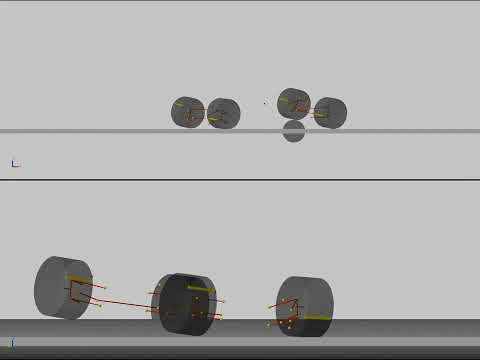
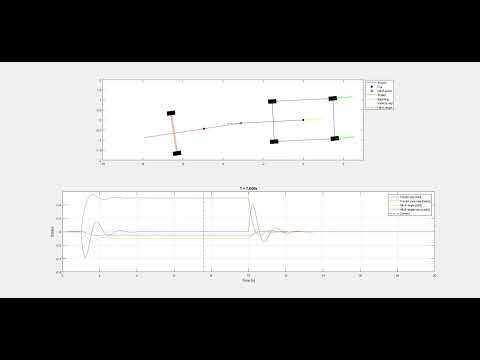
The video goes over the final demonstration.